|
I study contact-rich poly-articulated dexterous grasping and manipulation under uncertainty, connecting CBF-based safe control, risk-sensitive planning, latent uncertainty estimation, and safe policy learning to build robotic manipulation systems that handle uncertain object pose, friction, contact modes, and target geometry, as well as potentially-destabilizing wrenches that arise from whole-body motion or other task-space or exogenous sources. I validate these ideas in simulation (MuJoCo, Drake, Isaac Sim) and on real robot platforms (see Robots).
Click to enlarge.
Safe, Quality-Preserving Dexterous Grasping
SE(3)-Equivariant, Reach-Aware Grasp Synthesis
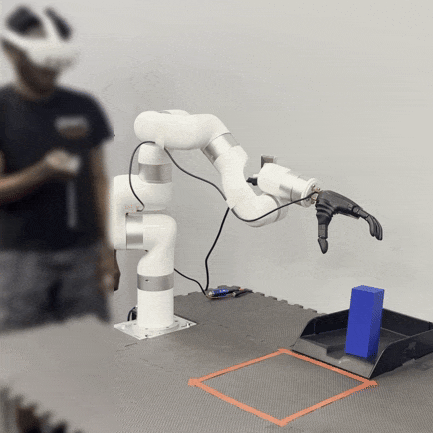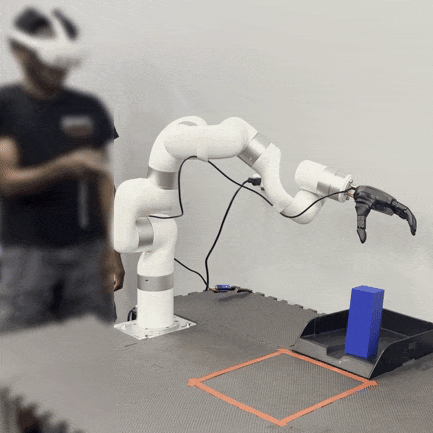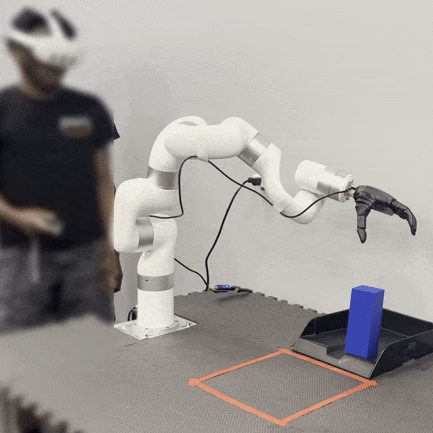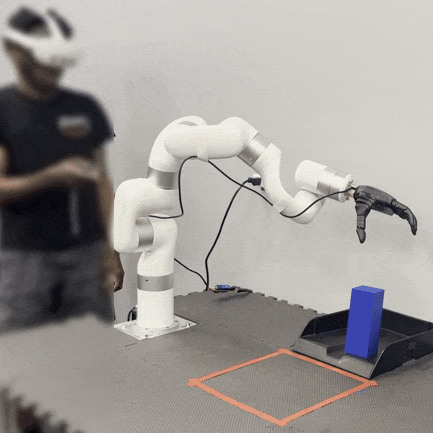
Safe Teleoperation & Manipulation Policy Rollout
Imitation-Learned Dexterous Manipulation
| [preprint] | Our new study on robustness preservation in imitation-learned dexterous manipulation under execution speed variation reveals hidden policy fragility that typical success-based evaluations miss. |
| [preprint] | We introduced a CBF-CLF-based control framework for safe and planner-free dexterous grasping with safe-set forward invariance and grasp quality preservation: Grasp Distance Fields. |
| [paper] | Our paper introducing a CVaR-based belief-space MPPI algorithm for safe control has been accepted for presentation at CDC 2026. Links: demos, arXiv. |
| [preprint] | New preprint on FIRMGrasp introducing a novel grasp quality metric (ε(β)) for robust grasp synthesis under uncertain friction. Grasps certified by ε(β) achieve a 70% lift success rate under lateral pull, compared to 25% for grasps certified by the nominal Ferrari-Canny margin but are rejected by ε(β). |
| [paper] | VNB-Grasp, our variational neural belief framework for robust dexterous grasping under visuo-tactile uncertainty, has been accepted to IROS 2026. Links: code, arXiv. |
| [model] | If you work on learning-based dexterous manipulation, have a look at EquiDexFlow, our SE(3)-equivariant flow-matching model for synthesizing contact-aware multi-fingered grasps. To our knowledge, EquiDexFlow is the first learned dexterous grasp generator to produce articulated hand configuration, fingertip contacts, contact normals, and friction-constrained contact forces jointly within one end-to-end SE(3)-equivariant VAE architecture. |