I study dexterous grasping and contact-rich manipulation under uncertainty using optimization, belief-space planning, and robot learning.
Research Overview
I study contact-rich poly-articulated dexterous grasping and manipulation under uncertainty. My research combines optimization-based control, kinodynamic motion planning, belief estimation, and policy learning to address uncertain object pose, friction, contact modes, and target geometry. A central question is how a robot can acquire and retain a grasp, establish and change contact, and complete manipulation while satisfying collision-avoidance and task constraints. I investigate these questions with fixed-base serial-chain manipulators, bimanual robot manipulators, and humanoids.
My earlier doctoral work addressed robust stochastic planning, safety-critical control using Boolean combinations of control barrier functions, distributional reinforcement learning, and distributed multi-agent coordination under uncertainty. These studies connect stochastic decision-making with safety and coordination constraints. The reinforcement learning studies include my risk-sensitive algorithms, reproductions of published methods, and integration of learned policies with robot feedback control.
current work
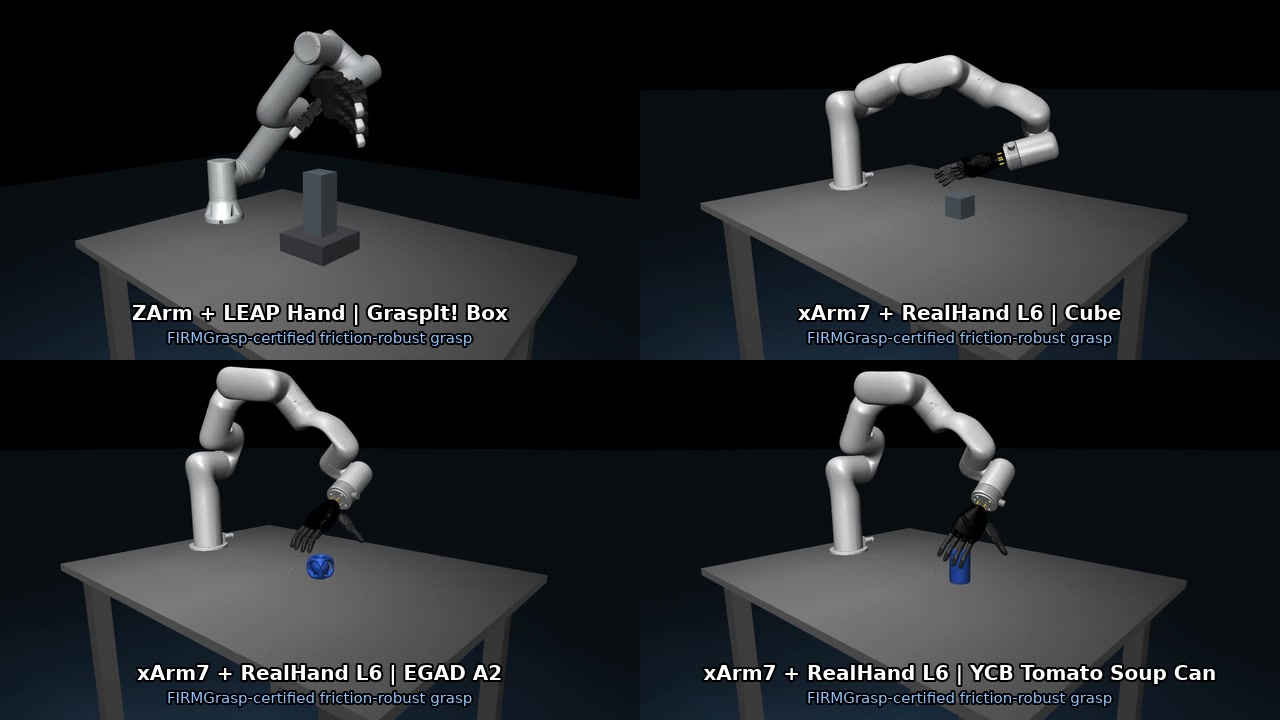
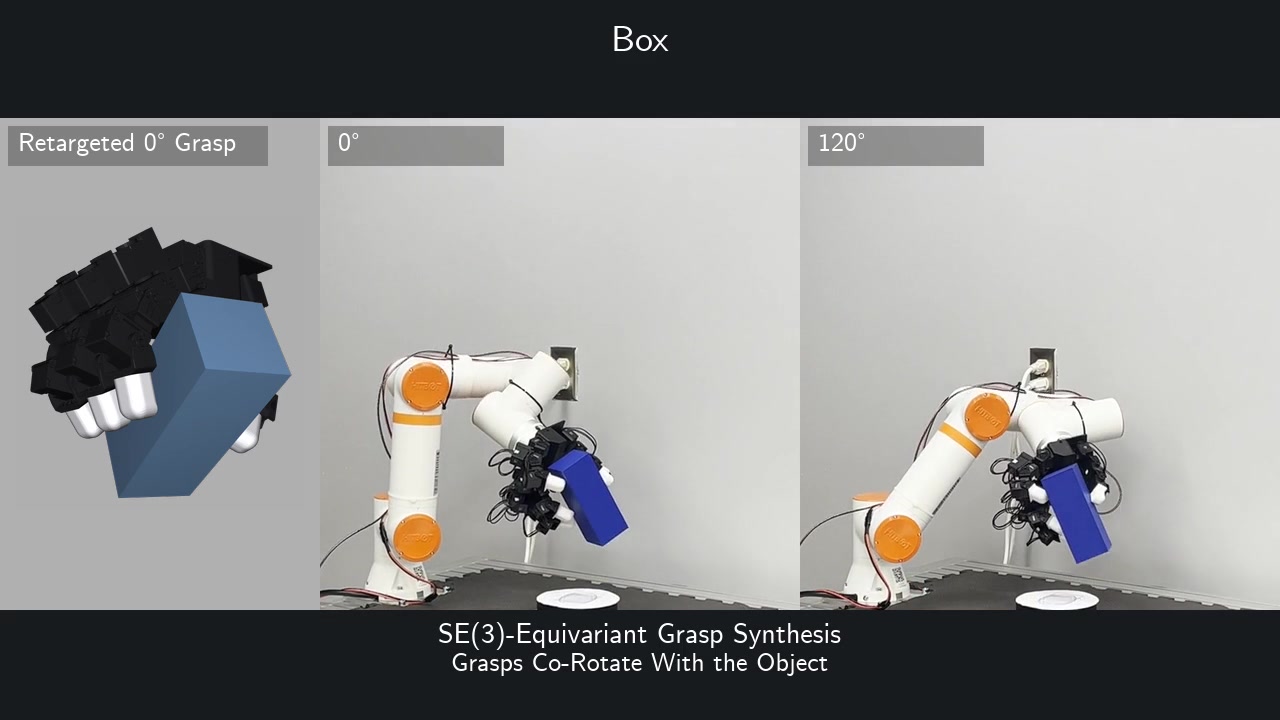
My grasping research addresses both grasp synthesis and feedback execution. I develop SE(3)-equivariant generative models for articulated hand configurations and object contacts, and differentiable belief representations for risk-sensitive grasp optimization under uncertain contact parameters. For grasp execution, I study feedback grasp selection, collision avoidance through control barrier functions, and preservation of grasp quality without a precomputed trajectory.
My manipulation research examines how uncertainty and changing contact conditions affect task completion. The model-based work includes risk-sensitive belief-space control for dexterous stowing and belief-informed hybrid control for bimanual assembly.
In ParcelStow, we compare expert and learned-policy success rates under variation in execution timing. My learning research includes ACT, diffusion policies, and residual reinforcement learning for bimanual manipulation. I also fine-tune vision-language-action models for monitoring task progress and triggering recovery from visuo-tactile feedback. A longer-term objective is to combine geometric structure, uncertainty estimation, and multimodal observations in manipulation policies that account explicitly for performance, robustness, and safety under partial observability.
I evaluate these methods in MuJoCo, Drake, and Isaac Sim, and through hardware experiments on the platforms listed on the Robots page.
Applications
Select a theme to browse its demonstrations; select a video to enlarge it.
Grasp Planning and Contact-Rich ManipulationGrasp synthesis, reactive grasp execution, visuo-tactile-guided planning, and contact-rich bimanual manipulation.4 Demos
Whole-Body Dexterous Grasp and Manipulation Planning
DexReach is a GPU-accelerated Python package built on NVIDIA cuRobo for whole-body dexterous grasp and manipulation planning. The videos demonstrate grasping, pick-and-place, object reorientation, and bimanual manipulation in Isaac Lab.
Visuo-Tactile Bimanual Planning and Wrench-Aware Control
Autonomous bimanual assembly using depth-based pose estimation, collision-constrained joint-space trajectory optimization, tactile-informed and gravity-compensated position control, and wrench-aware control.
Robot Learning and TeleoperationReinforcement and imitation learning, vision-language-action models, manipulation policy evaluation, and hardware teleoperation for contact-rich tasks.8 Demos
Reinforcement Learning
I reproduced DAPG relocation results in MuJoCo / Adroit: 95/100 successful episodes with deterministic action selection and 98/100 with stochastic actions, compared with 0/100 for behavior cloning in both modes.
VR-assisted hardware teleoperation with single-arm workspace-boundary enforcement and two bimanual tasks, constrained object relocation and key–housing insertion. The insertion panel shows the left hand stabilizing the housing while the right hand seats the key.
Clinton Enwerem, Saleh Kemal, John S. Baras, and Calin Belta, “Improving Imitation Policies for Multi-Phase Tasks through Residual Learning Allocation,” arXiv preprint, 2026. arXiv link
@misc{enwerem_residual_allocation_2026,
  title = {Improving Imitation Policies for Multi-Phase Tasks through Residual Learning Allocation},
  author = {Enwerem, Clinton and Kemal, Saleh and Baras, John S. and Belta, Calin},
  year = {2026},
  eprint = {2611.25320},
  archivePrefix = {arXiv},
  primaryClass = {cs.LG},
  url = {https://arxiv.org/abs/2611.25320}
}
arXiV
Clinton Enwerem, Saleh Kemal, John S. Baras, and Calin Belta, “Belief-Informed Hybrid Control with Almost-Sure Target-Set Convergence,” arXiv preprint, 2026. arXiv link
@misc{enwerem2026beliefinformedhybrid,
  title = {Belief-Informed Hybrid Control with Almost-Sure Target-Set Convergence},
  author = {Enwerem, Clinton and Kemal, Saleh and Baras, John S. and Belta, Calin},
  year = {2026},
  eprint = {2610.07674},
  archivePrefix = {arXiv},
  primaryClass = {eess.SY},
  doi = {10.48550/arXiv.2610.07674},
  url = {https://arxiv.org/abs/2610.07674}
}
arXiV
Clinton Enwerem, John S. Baras, and Calin Belta, “Does Imitation Learning Preserve Temporal Robustness in Dexterous Manipulation? An Expert-Learner Comparison Across Task Execution Speeds,” arXiv preprint, 2026. arXiv link
@online{enweremDoesImitationLearningPreserve2026,
title = {Does Imitation Learning Preserve Temporal Robustness in Dexterous Manipulation? An Expert-Learner Comparison Across Task Execution Speeds},
author = {Enwerem, Clinton and Baras, John S. and Belta, Calin},
year = {2026},
eprint = {2609.01453},
eprinttype = {arXiv},
eprintclass = {cs.RO},
doi = {},
url = {https://arxiv.org/abs/2609.01453},
pubstate = {prepublished},
keywords = {Computer Science - Robotics},
}
arXiV
Clinton Enwerem, John S. Baras, and Calin Belta, “Grasp Execution Without a Planner: Configuration-Space Grasp Distance Fields with Certified Safety & Guaranteed Quality,” arXiv preprint, 2026. arXiv link
@online{enweremGraspDistanceFields2026,
title = {Grasp Execution Without a Planner: Configuration-Space Grasp Distance Fields with Certified Safety \& Guaranteed Quality},
author = {Enwerem, Clinton and Baras, John S. and Belta, Calin},
year = {2026},
eprint = {2608.00600},
eprinttype = {arXiv},
eprintclass = {cs.RO},
doi = {10.48550/arXiv.2608.00600},
url = {https://arxiv.org/abs/2608.00600},
pubstate = {prepublished},
keywords = {Computer Science - Robotics, Electrical Engineering and Systems Science - Systems and Control, Mathematics - Optimization and Control},
}
arXiV
Clinton Enwerem, John S. Baras, and Calin Belta, “FIRMGrasp: A Friction-Informed Risk Margin for Robust Grasp Synthesis,” arXiv preprint, 2026. arXiv link
@online{enweremFIRMRobustGraspSynthesis2026,
title = {FIRMGrasp: A Friction-Informed Risk Margin for Robust Grasp Synthesis},
author = {Enwerem, Clinton and Baras, John S. and Belta, Calin},
year = {2026},
eprint = {2607.25049},
eprinttype = {arXiv},
eprintclass = {cs.RO},
doi = {},
url = {https://arxiv.org/abs/2607.25049},
pubstate = {prepublished},
keywords = {Computer Science - Robotics, Computer Science - Machine Learning},
}
arXiV
Clinton Enwerem, John S. Baras, and Calin Belta, “EquiDexFlow: Contact-Grounded SE(3)-Equivariant Dexterous Grasp Generative Flows,” arXiv preprint, 2026. arXiv link
@online{enweremEquiDexFlowContactGroundedSE32026,
title = {EquiDexFlow: Contact-Grounded SE(3)-Equivariant Dexterous Grasp Generative Flows},
author = {Enwerem, Clinton and Baras, John S. and Belta, Calin},
year = {2026},
eprint = {2606.12728 [cs.RO]},
eprinttype = {arXiv},
eprintclass = {cs.RO},
doi = {10.48550/arXiv.2606.12728},
url = {http://arxiv.org/abs/2606.12728},
pubstate = {prepublished},
keywords = {Computer Science - Robotics, Computer Science - Machine Learning},
}
Peer-Reviewed
2026
CDC
Clinton Enwerem, John S. Baras, and Calin Belta, “Risk-Constrained Belief-Space Optimization for Safe Control under Latent Uncertainty,” To appear in the Proceedings of the 65th IEEE Conference on Decision and Control (CDC), 2026.
@misc{enweremRiskConstrainedBeliefSpaceOptimization2026a,
  title      = {{Risk-Constrained Belief-Space Optimization for Safe Control under Latent Uncertainty}},
  author     = {Enwerem, Clinton and Baras, John S. and Belta, Calin},
  year       = {2026},
  month      = dec,
  eprint     = {2604.03868},
  eprinttype = {arxiv},
  url        = {http://arxiv.org/abs/2604.03868},
  doi        = {10.48550/arXiv.2604.03868},
  note       = {\textit{To appear in the Proceedings of the 65th IEEE Conference on Decision and Control (CDC).} {\href{http://arxiv.org/abs/2604.03868}{\extlink{arXiV Link}}}},
}
IROS
Clinton Enwerem, Shreya Kalyanaraman, John S. Baras, and Calin Belta, “Variational Neural Belief Parameterizations for Robust Dexterous Grasping under Multimodal Uncertainty,” In the Proceedings of the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 3117–3124, 2026.
@inproceedings{enweremVariationalNeuralParameterizations2026a,
  title      = {{Variational Neural Belief Parameterizations for Robust Dexterous Grasping under Multimodal Uncertainty}},
  author     = {Enwerem, Clinton and Kalyanaraman, Shreya and Baras, John S. and Belta, Calin},
  booktitle  = {2026 {IEEE/RSJ} {International} {Conference} on {Intelligent} {Robots} and {Systems} ({IROS})},
  pages      = {3117--3124},
  address    = {Pittsburgh, PA, USA},
  eventdate  = {2026-09-27/2026-10-01},
  month      = sep,
  year       = {2026},
  eprint     = {2604.25897},
  eprinttype = {arxiv},
  url        = {http://arxiv.org/abs/2604.25897},
  doi        = {10.48550/arXiv.2604.25897},
  note       = {{\href{http://arxiv.org/abs/2604.25897}{\extlink{arXiV Link}}}},
}
2025
CDC
Clinton Enwerem, Aniruddh G. Puranic, John S. Baras, and Calin Belta, “Safety-Aware Reinforcement Learning for Control via Risk-Sensitive Action-Value Iteration and Quantile Regression,” In the Proceedings of the 2025 IEEE 64th Conference on Decision and Control (CDC), pp. 4890–4895, 2025.
@inproceedings{enwerem2025safety,
  title     = {{Safety-Aware Reinforcement Learning for Control via Risk-Sensitive Action-Value Iteration and Quantile Regression}},
  author    = {Enwerem, Clinton and Puranic, Aniruddh G. and Baras, John S. and Belta, Calin},
  booktitle = {2025 {IEEE} 64th Conference on Decision and Control (CDC)},
  pages     = {4890--4895},
  year      = {2025},
  month     = dec,
  doi       = {10.1109/CDC57313.2025.11312575},
  note      = {{\href{http://arxiv.org/abs/2506.06954}{\extlink{arXiV Link}}}},
}
2024
CDC
Clinton Enwerem, Erfaun Noorani, John S. Baras, and Brian M. Sadler, “Robust Stochastic Shortest-Path Planning via Risk-Sensitive Incremental Sampling,” In the Proceedings of the 2024 IEEE 63rd Conference on Decision and Control (CDC), pp. 1087–1094, 2024.
@inproceedings{enwerem2024robust,
  title     = {{Robust Stochastic Shortest-Path Planning via Risk-Sensitive Incremental Sampling}},
  author    = {Enwerem, Clinton and Noorani, Erfaun and Baras, John S. and Sadler, Brian M.},
  booktitle = {2024 {IEEE} 63rd Conference on Decision and Control (CDC)},
  pages     = {1087--1094},
  year      = {2024},
  month     = dec,
  doi       = {10.1109/CDC56724.2024.10886577},
  note      = {{\href{http://arxiv.org/abs/2408.08668}{\extlink{arXiV Link}}}},
}
ECC
Clinton Enwerem and John S. Baras, “Safe Collective Control under Noisy Inputs and Competing Constraints via Non-Smooth Barrier Functions,” In the Proceedings of the 2024 European Control Conference (ECC), pp. 3762–3768, 2024.
@inproceedings{enwerem2024safe,
  title     = {{Safe Collective Control under Noisy Inputs and Competing Constraints via Non-Smooth Barrier Functions}},
  author    = {Enwerem, Clinton and Baras, John S.},
  booktitle = {2024 {European} Control Conference (ECC)},
  pages     = {3762--3768},
  year      = {2024},
  month     = jun,
  eprint    = {2311.03284},
  eprinttype = {arxiv},
  doi       = {10.23919/ECC64448.2024.10591027},
}
LCSS
Clinton Enwerem and John S. Baras, “Formation Tracking for a Class of Uncertain Multiagent Systems: A Distributed Kalman Filtering Approach,” IEEE Control Systems Letters, Volume 8, 2024.
@article{enweremFormationTrackingDistributedKalmanFiltering2023,
  title = {{Formation Tracking for a Class of Uncertain Multiagent Systems: A Distributed Kalman Filtering Approach}},
  author = {Enwerem, Clinton and Baras, John S.},
  year = {2024},
  journal = {IEEE Control Systems Letters},
  volume=8,
  abstract = {Current approaches to estimating the states of agents in multiagent formation tracking relies heavily on either filtering local observations from sensors fitted on each agent, or observations from external sensors in an inertial frame of reference. Such approaches are largely unreliable, centralized, and not practical for real-life settings. Accordingly, we propose a formation tracking scheme that relies on distributed Kalman filtering (DKF) to obtain agents' states. Our approach exploits the underlying shared network to reconstruct the state of each agent by pooling relative state measurements from its neighbors in the network. A weighted consensus-like control law, defined in terms of the computed relative state estimates, is consequently applied to achieve formation maintenance, and a trajectory-error-minimizing controller is designed for the tracking component. Finally, to validate our proposed technique, we present results from numerical simulations and real multi-robot experiments.},
  langid = {english},
}
2023
CoDIT
Clinton Enwerem and John S. Baras, “Consensus-Based Leader-Follower Formation Tracking for Control-Affine Nonlinear Multiagent Systems,” In the Proceedings of the 9th International Conference on Control, Decision and Information Technologies (CoDIT), 2023.
@inproceedings{enweremConsensusBasedFormationTracking2023,
  title     = {{Consensus-Based Leader-Follower Formation Tracking for Control-Affine Nonlinear Multiagent Systems}},
  author    = {Enwerem, Clinton and Baras, John S.},
  booktitle = {9th International Conference on Control, Decision and Information Technologies (CoDIT)},
  year      = {2023},
  month     = jul,
  eprint    = {2309.09156},
  eprinttype = {arxiv},
  doi       = {10.1109/CoDIT58514.2023.10284199},
}