|
Click to enlarge.
ParcelStow evaluates how dexterous manipulation policies respond to changes in task execution rate. The Isaac Lab benchmark includes three contact-rich tasks for the Unitree G1 with RealHand L6 hands, with scripted experts and ACT policies evaluated under matched conditions. Custom policies can use the same evaluation, and we provide scripts for reproducing our paper's experiments.
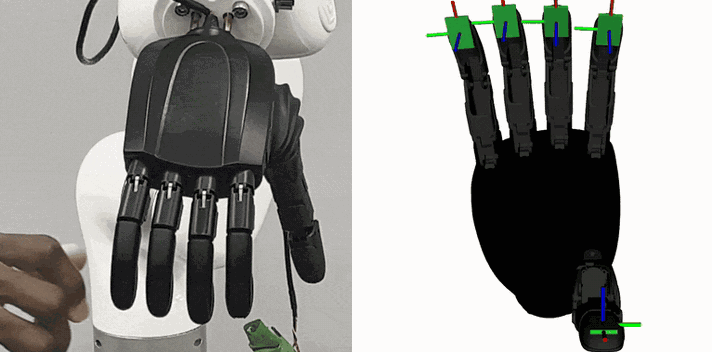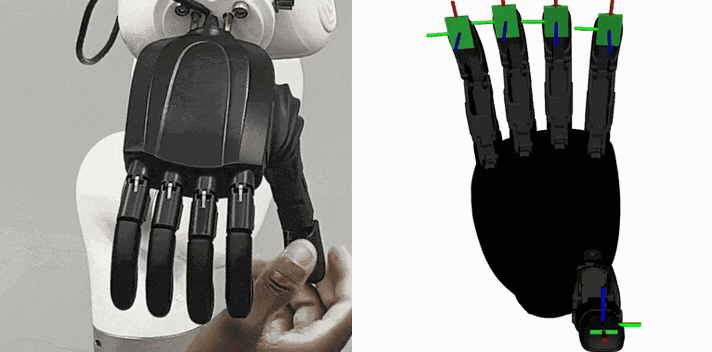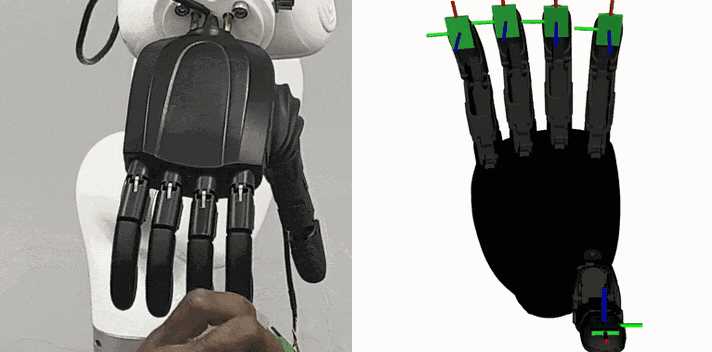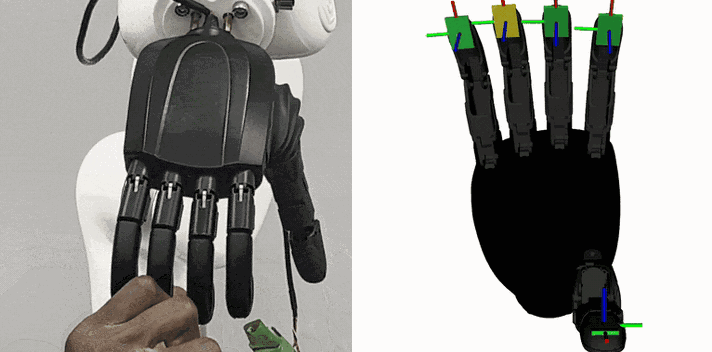
realhand_l6_ros2 controls the RealHand L6 dexterous hand over SocketCAN and detects fingertip contact from tactile sensing in ROS 2 Jazzy. The package includes the control driver, tactile controller, robot description, hardware bringup, and MoveIt configuration. The CAN protocol implementation and tactile contact controller are validated on a physical right-hand unit.
kinematic_planner_ros2 computes collision-free paths for serial-chain manipulators with N degrees of freedom using sampling-based planning in ROS 2. It uses FCL for collision checking and the Robotics Toolbox for Python for kinematics, with optional MuJoCo visualization. Robot and scene descriptions use URDF, and the planner can be configured via ROS 2 parameters.
EquiDexFlow generates reach-aware, collision-free dexterous grasps using contact-grounded SE(3)-equivariant flow matching. It jointly predicts articulated hand configuration, fingertip contacts, contact normals, and friction-constrained contact forces within one end-to-end SE(3)-equivariant architecture.
VNB-Grasp computes pathwise conditional value-at-risk (CVaR) gradients for risk-sensitive dexterous grasping under uncertain contact parameters and object pose. VNB-Grasp adopts a differentiable Gaussian-mixture belief uncertainty representation and includes a MuJoCo benchmark for measuring friction sensitivity and perturbation tolerance.
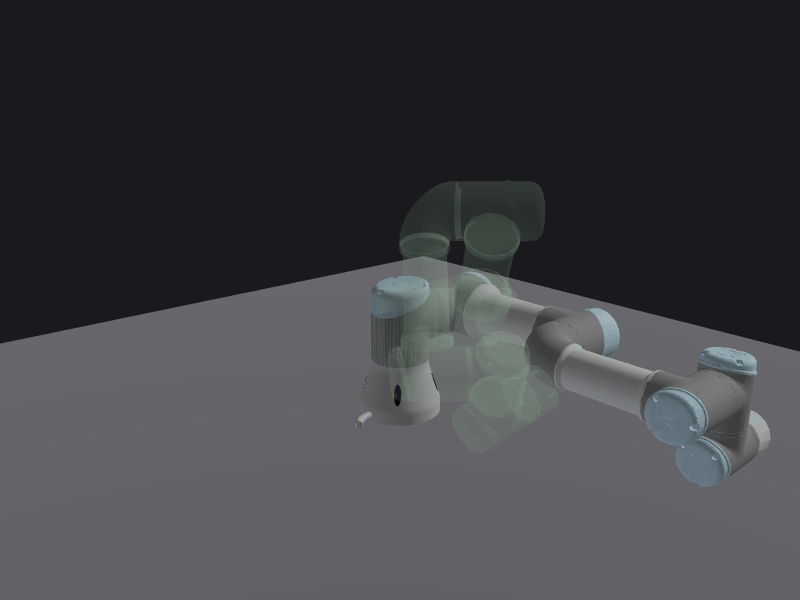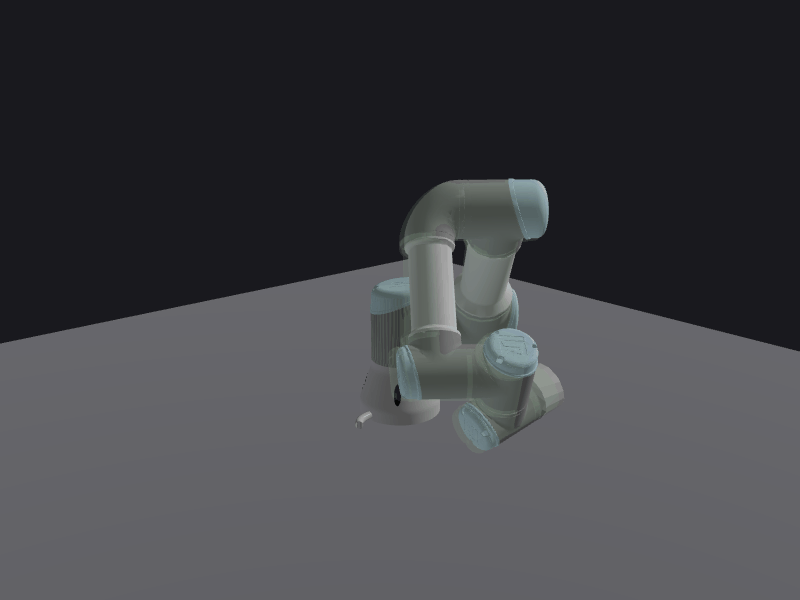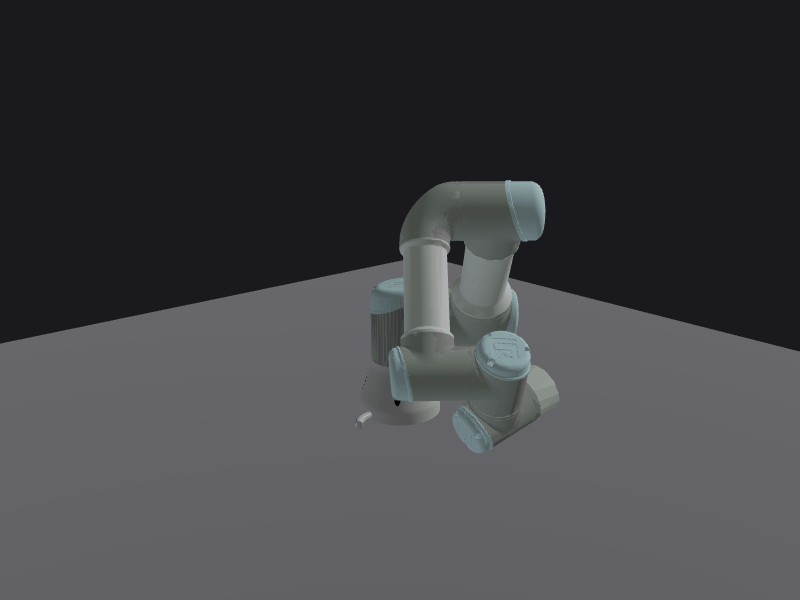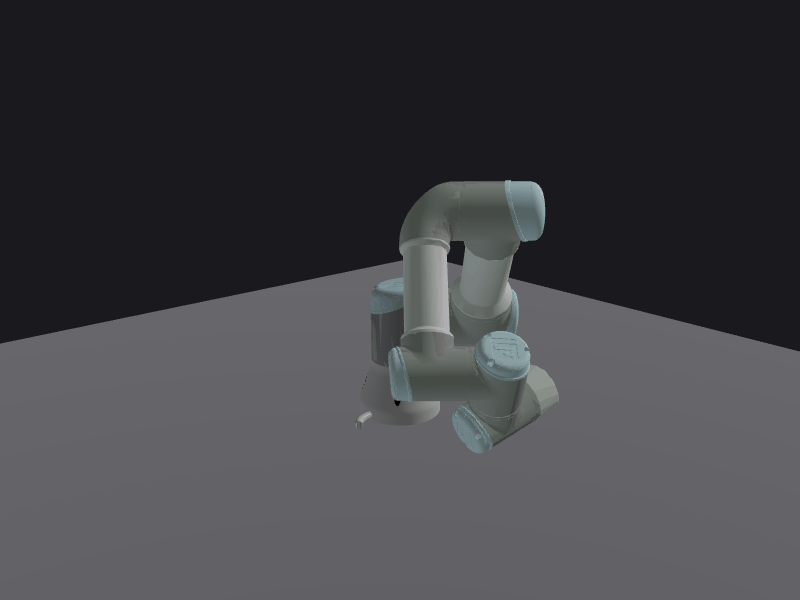
Simple URDF Parser computes forward and inverse kinematics and Jacobians from URDF robot descriptions in Python. The library includes an interactive 3D visualizer.