GraspIt! Python Wrapper
The GraspIt! Python Wrapper provides direct access to the GraspIt! simulator for planning and evaluating grasps with multifingered hands. See Miller and Allen for the simulator’s design. A Python program can set the palm pose and finger coordinates, invoke closure, and retrieve object-frame contact positions and normals. This interface makes each simulated closure available for inspection and external scoring. A planner built on the interface enumerates approaches and ranks their closures by general-purpose or task-specific wrench capacity under approach and friction uncertainty.
The MuJoCo exporter produces GraspIt! robot and object models from a compiled MuJoCo scene. It records the joint and link correspondence needed to transfer planned configurations to the source model. The application uses the resulting targets for arm kinematics, motion planning, and execution. The source repository contains the code and examples. See Citation and References for software citation metadata and the arXiv preprint (coming soon).
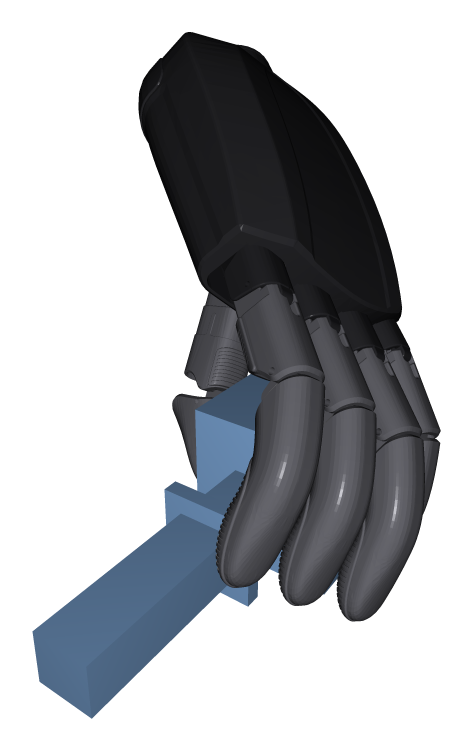
RealHand L6. Planned key grasp.
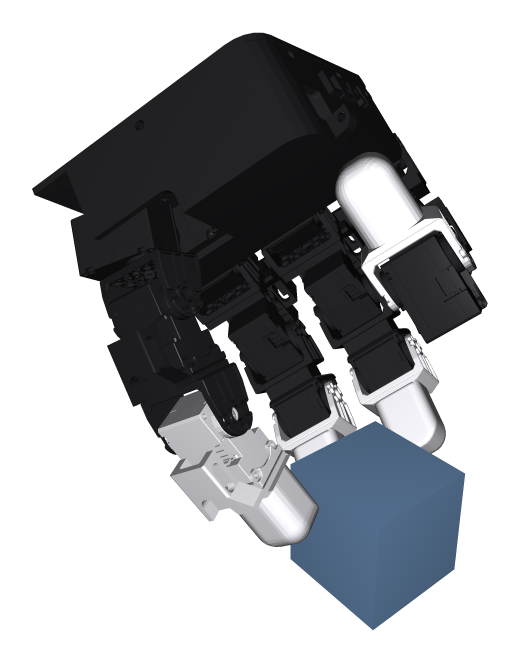
LEAP Hand. Simulated cube hold.
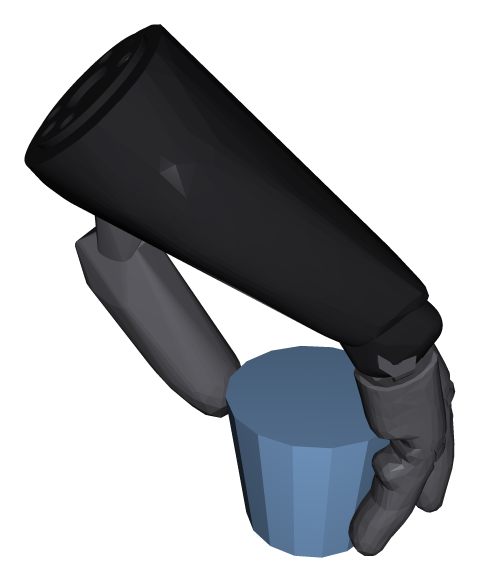
PSYONIC Ability Hand. Simulated cylinder hold.
Start with Installation and the RealHand L6 walkthrough. The planning guide explains approach specification, task loading, and the grasp records shown above. The export guide covers model conversion and transfer back to MuJoCo. The theory guide derives the joint mapping and wrench scores used in both guides.
Build the Manual
The documentation build requires Python 3.11 or later. Run the following commands from the wrapper repository root.
python3 -m venv .venv-docs
.venv-docs/bin/python -m pip install -r docs/requirements.txt
.venv-docs/bin/python -m sphinx -nW -b html docs docs/_build/html
Open docs/_build/html/index.html.