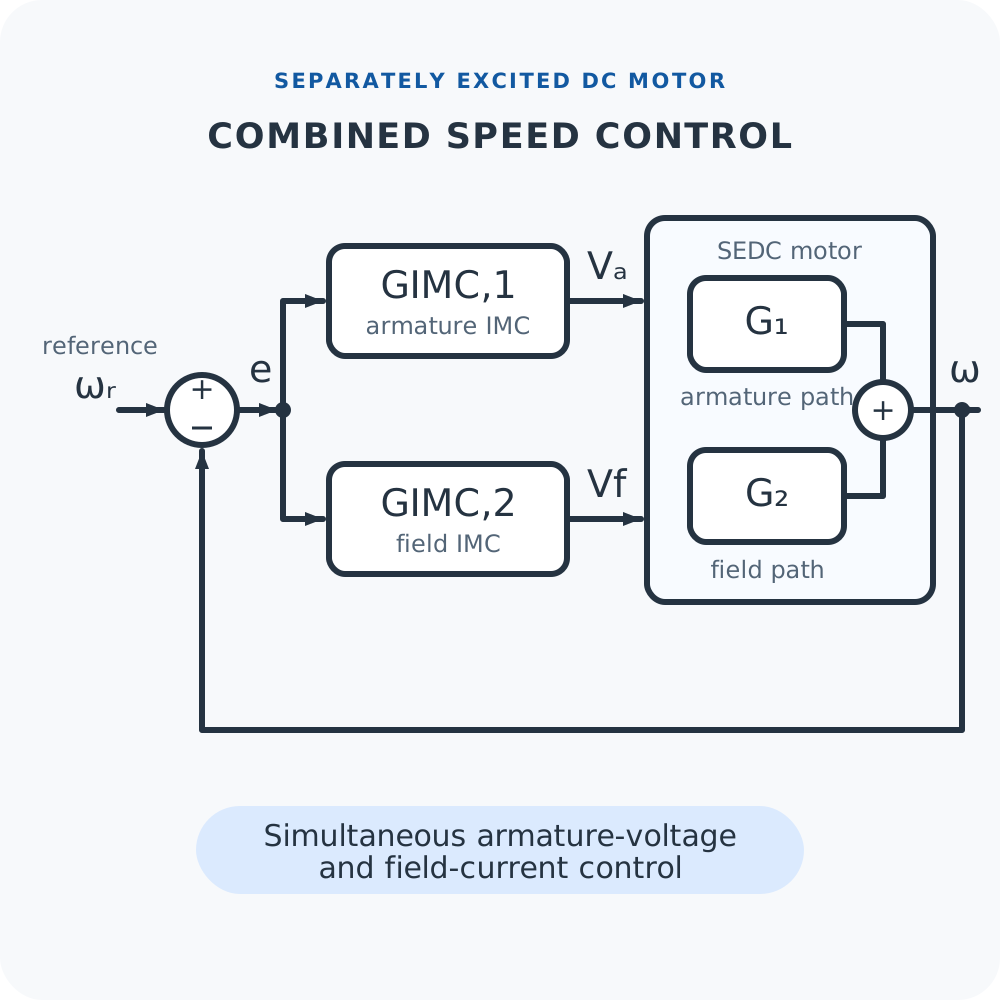
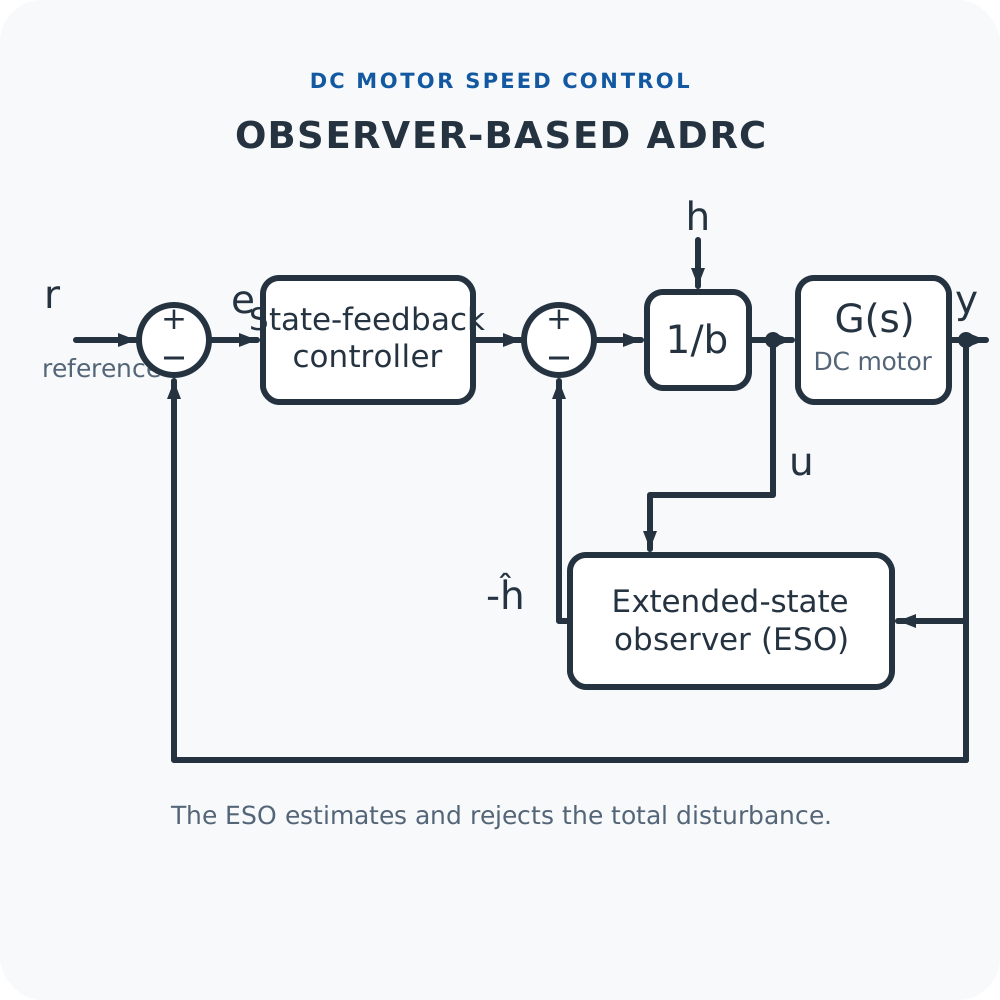
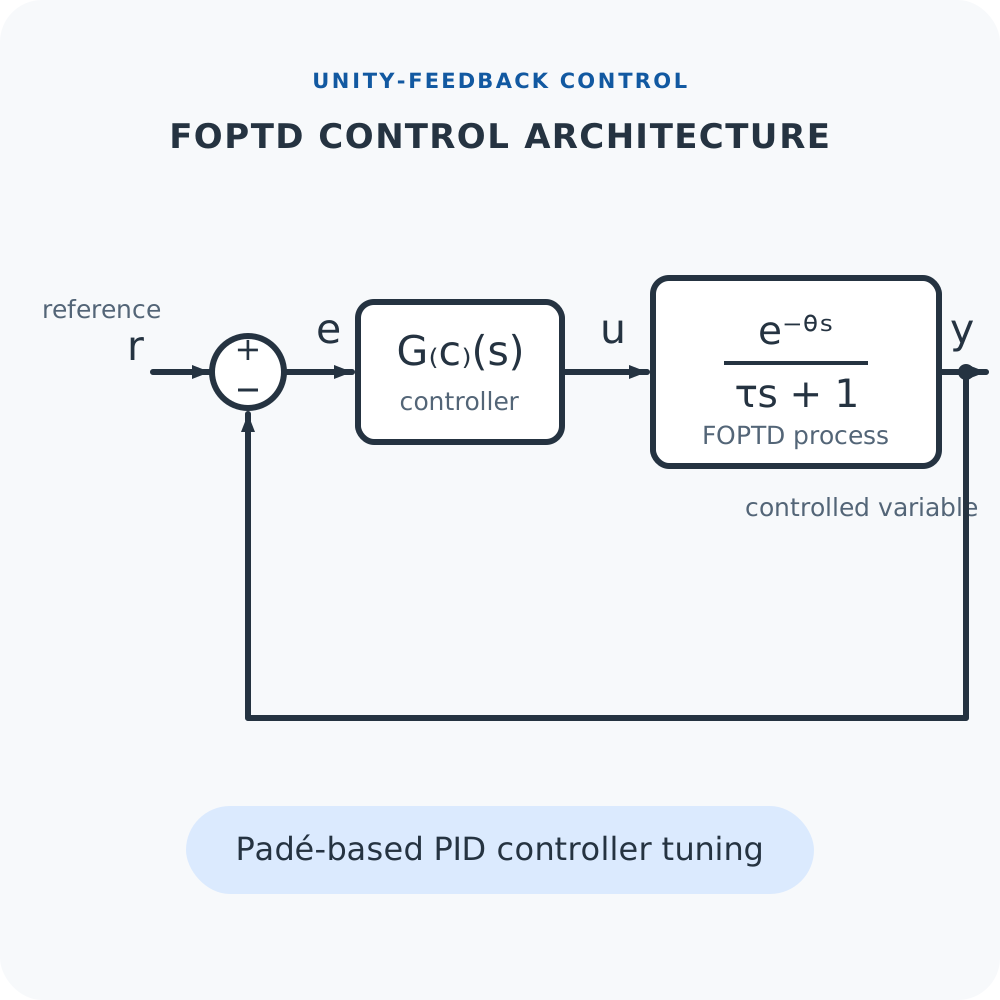
The publications below predate my doctoral work in robotic manipulation. I have included them here for archival purposes only. My earliest exposure to controls research occurred during my undergraduate studies at the University of Nigeria, in Engr. Ihechiluru Okoro's Control Systems Engineering (EE472) course. There, I completed a project focused on feedback control design for first-order processes with time delay (FOPTD). Results from this project later grew into the second arXiv preprint below, which proposed a Padé-approximation-based PID tuning technique for FOPTD systems. My undergraduate thesis, advised by Dr. Udoka Nwaneto, subsequently focused on model-based controller synthesis for speed regulation in electric drives. The two joint papers below were independent studies built on the same DC motor model, assumptions, and, in part, MATLAB/Simulink code. The first developed a novel combined armature-field speed-control scheme for a separately-excited DC motor, while the second introduced an observer-based active disturbance rejection controller for eliminating unknown disturbances while preserving closed-loop bandwidth and stability margins. After graduating, I spent a year at Robotics and Artificial Intelligence Nigeria, where I worked with Dr. Olusola Ayoola on robot navigation and monocular visual SLAM, before joining Kognitive Robotics as a robotics engineer developing ground-based, differentially-driven mobile robotic platforms. Collectively, these research efforts solidified the foundational principles of modeling, control, estimation, and simulation that guided my early doctoral work with Prof. John S. Baras at the University of Maryland, focusing on multi-agent coordination and control, specifically, quadrotor leader-follower formation tracking under localization uncertainty and communication packet drops.
Research Themes
Click to enlarge.
Formation Tracking with Nano-Sized Quadrotors
Combined Armature-Field DC Motor Control
ADRC for DC Motor Speed Control
Padé-Based PID Tuning for FOPTD Systems
Publications
2023
arXiV
Clinton Enwerem, John Baras, and Danilo Romero, “Distributed Optimal Formation Control for an Uncertain Multiagent System in the Plane,” arXiv preprint, 2023. arXiv link
@online{enweremDistributedFormationControl2023,
title = {Distributed Optimal Formation Control for an Uncertain Multiagent System in the Plane},
author = {Enwerem, Clinton and Baras, John and Romero, Danilo},
year = {2023},
eprint = {2301.05841},
eprinttype = {arXiv},
eprintclass = {eess.SY},
doi = {},
url = {https://arxiv.org/abs/2301.05841},
pubstate = {prepublished},
keywords = {Electrical Engineering and Systems Science - Systems and Control, Computer Science - Multiagent Systems},
}
2022
arXiV
Clinton Enwerem and Ihechiluru Okoro, “Optimal Controller Tuning Technique for a First-Order Process with Time Delay,” arXiv preprint, 2022. arXiv link
@online{enweremOptimalControllerTuningTechnique2022,
title = {Optimal Controller Tuning Technique for a First-Order Process with Time Delay},
author = {Enwerem, Clinton and Okoro, Ihechiluru},
year = {2022},
eprint = {2210.08187},
eprinttype = {arXiv},
eprintclass = {eess.SY},
doi = {},
url = {https://arxiv.org/abs/2210.08187},
pubstate = {prepublished},
keywords = {Electrical Engineering and Systems Science - Systems and Control, Mathematics - Optimization and Control},
}
2020
Heliyon
Ihechiluru S. Okoro and Clinton O. Enwerem, “Robust Control of a DC Motor,” Heliyon, Volume 6, Issue 12, e05777, 2020.
@article{okoroRobustControlDCMotor2020,
title = {Robust Control of a DC Motor},
author = {Okoro, Ihechiluru S. and Enwerem, Clinton O.},
year = {2020},
journal = {Heliyon},
volume = {6},
number = {12},
pages = {e05777},
doi = {10.1016/j.heliyon.2020.e05777},
url = {https://doi.org/10.1016/j.heliyon.2020.e05777},
}
2019
IEEE
Ihechiluru Okoro and Clinton Enwerem, “Model-Based Speed Control of a DC Motor Using a Combined Control Scheme,” In the Proceedings of the 2019 IEEE PES/IAS PowerAfrica, 2019.
@inproceedings{okoroModelBasedControlDCMotor2019,
title = {Model-Based Speed Control of a DC Motor Using a Combined Control Scheme},
author = {Okoro, Ihechiluru and Enwerem, Clinton},
booktitle = {2019 IEEE PES/IAS PowerAfrica},
year = {2019},
doi = {10.1109/PowerAfrica.2019.8928856},
}